CW-MU4930
MEMS Inertial Measurement Unit
Product Overview
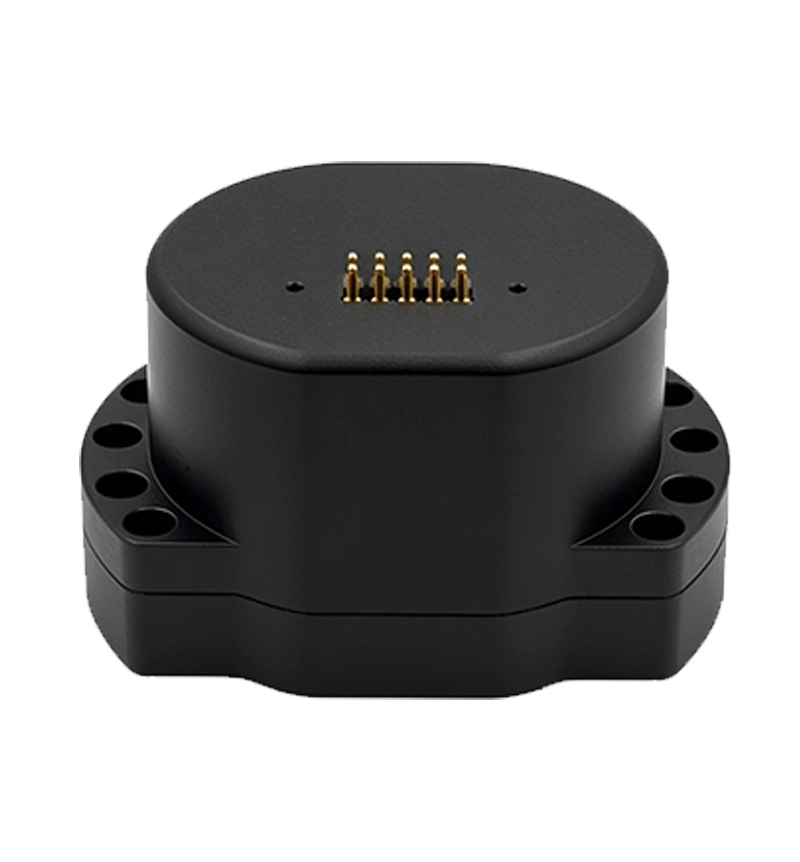
CW-MU4930 is a highly reliable, cost-effective six-axis MEMS inertial sensor. It is widely used in navigation, control and measurement fields represented by vehicles, ships and UAVs. The independently structured unit integrates high-performance MEMS gyroscopes and MEMS accelerometers. The gyroscopes and accelerometers selected for the system are at the highest level among MEMS process inertial devices.
Core Advantages
Pin-to-pin replacement for Honeywell HG4930; full-temperature calibration compensation from -45℃ to +80℃; support of online firmware upgrade; 100% domestic production; 12kHz high-speed sampling; capable of resisting harsh mechanical environments.
Key Features
- Pin-to-pin replacement for Honeywell HG4930
- -45℃ ~ +80℃ full-temperature calibration compensation
- Support software online upgrade
- 100% domestic production
- 12kHz high-speed sampling
- Resist harsh mechanical environments
Main Applications
- Vehicle navigation & attitude measurement
- Marine inertial measurement
- UAV flight control and navigation
- Precision motion measurement
- Inertial navigation control system
Performance Specifications
| Category | Parameter Item | CW-MU4930 |
|---|---|---|
| Gyroscope | Range (°/s) | ±400 |
| Full-temperature Bias (°/h) | ≤2 (Optional ≤1) | |
| Bias Stability (°/h, 10s smoothing) | ≤0.5 (Optional ≤0.3) | |
| Bias Stability (°/h, allan) | ≤0.05 | |
| Bias Repeatability (°/h) | ≤0.3 | |
| Angular Random Walk (°/√h) | ≤0.05 | |
| G-sensitive Error (°/s/g) | ≤0.0005 | |
| Cross-coupling (rad) | ≤0.001 | |
| Scale Factor Nonlinearity (ppm) | ≤100 | |
| Bandwidth (Hz, adjustable) | 100 | |
| Accelerometer | Range (g) | ±20 |
| Full-temperature Bias (mg, 1σ) | ≤1 | |
| Bias Stability (μg, 10s smoothing) | ≤100 | |
| Bias Stability (μg, allan) | ≤30 | |
| Bias Repeatability (μg) | ≤100 | |
| Scale Factor Nonlinearity (ppm) | ≤150 | |
| Cross-coupling (rad) | ≤0.001 | |
| Bandwidth (Hz, adjustable) | 100 | |
| Electrical & Mechanical Interface | Power Supply (V) | 5±0.2 |
| Power Consumption (W) | Typical 2, Max 3 | |
| Start-up Time (s) | 2 | |
| Communication Interface | 1 × RS-422, 1 × sync input, 1 × sync output | |
| Update Rate (Hz) | 200 | |
| Dimension (mm×mm×mm) | 64.8×47×35.3 | |
| Weight (g) | ≤165 | |
| Operating Environment | Operating Temperature (℃) | -45 ~ +80 |
| Storage Temperature (℃) | -55 ~ +85 |