CW-MSB1330
MEMS Integrated Inertial Navigation System
Product Overview
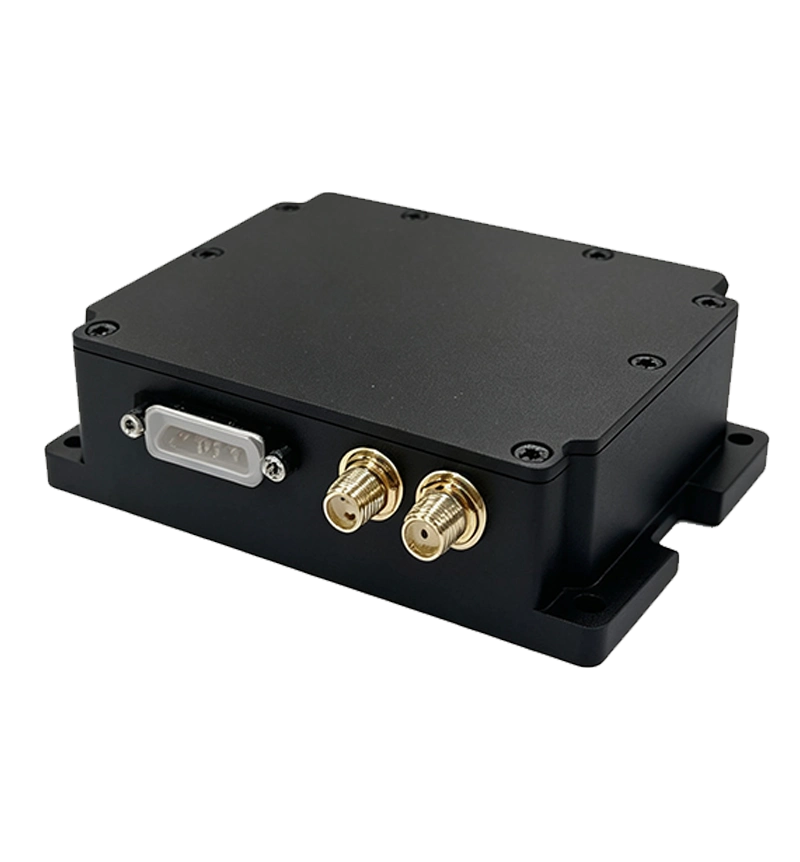
CW-MSB1330 integrates high-performance MEMS gyroscopes, MEMS accelerometers and GNSS satellite receiver chips. By sensing the angular rate and acceleration of carrier motion, it receives real-time data from GNSS dual antennas or heading angle, and performs navigation calculation to obtain real-time carrier heading angle, 3D velocity, position and attitude information.
Core Advantages
Full-band GNSS support, ultra-low 3W power consumption, built-in adaptive attitude algorithm. When GNSS signal is lost, self-correction algorithm maintains horizontal attitude accuracy. Supports RTK differential input, zero velocity update and vehicle constraint algorithm.
Key Features
- Supports full-band GNSS
- Ultra-low power consumption: 3W
- Built-in adaptive attitude algorithm
- Self-correction algorithm maintains attitude without GNSS
- Compatible with RTK differential correction
- Zero velocity update & vehicle constraint algorithm
Main Applications
- Vehicle positioning and attitude measurement
- Mobile mapping and surveying
- Unmanned ground vehicle navigation
- Marine shallow water measurement
- Dynamic attitude reference system
Performance Specifications
| Category | Parameter Item | CW-MSB1330 |
|---|---|---|
| Integrated Navigation Accuracy | Combined Heading (°,1σ, real-time) | 0.15 (1m baseline dual-antenna) 0.5 (single antenna, dynamic) |
| Combined Horizontal Attitude (°,1σ, real-time) | 0.05° (Dual-antenna) 0.1° (Single antenna) |
|
| Combined Horizontal Position (m,1σ) | 3m (Single point) 0.02+1ppm (RTK) |
|
| Combined Vertical Position (m,1σ) | 5m (Single point) 0.03+1ppm (RTK) |
|
| Combined Horizontal Velocity (m/s,1σ) | 0.1 | |
| Combined Vertical Velocity (m/s,1σ) | 0.15 | |
| Pure Inertial Accuracy | Horizontal Attitude (°,1σ, real-time) | 0.05° (Static) 0.5° (Dynamic) |
| Heading (°,1σ, real-time) | 5° (Dynamic) | |
| Depth Measurement Accuracy (cm) | 5 | |
| Inertial / Odometer Dead Reckoning | ≤ 0.001D | |
| Electrical & Mechanical Interface | Power Supply (V) | 9~36 |
| Steady-state Power (W) | ≤ 3 | |
| Start-up Time (s) | ≤ 2 | |
| Communication Interface | 1×RS-422, 1×RS-232, 1×CAN | |
| Update Rate (Hz) | 200 (Customizable) | |
| Dimension (mm×mm×mm) | 83×66×23.8 | |
| Weight (g) | ≤ 350 | |
| Operating Environment | Operating Temperature (℃) | -45 ~ +80 |
| Storage Temperature (℃) | -55 ~ +85 |