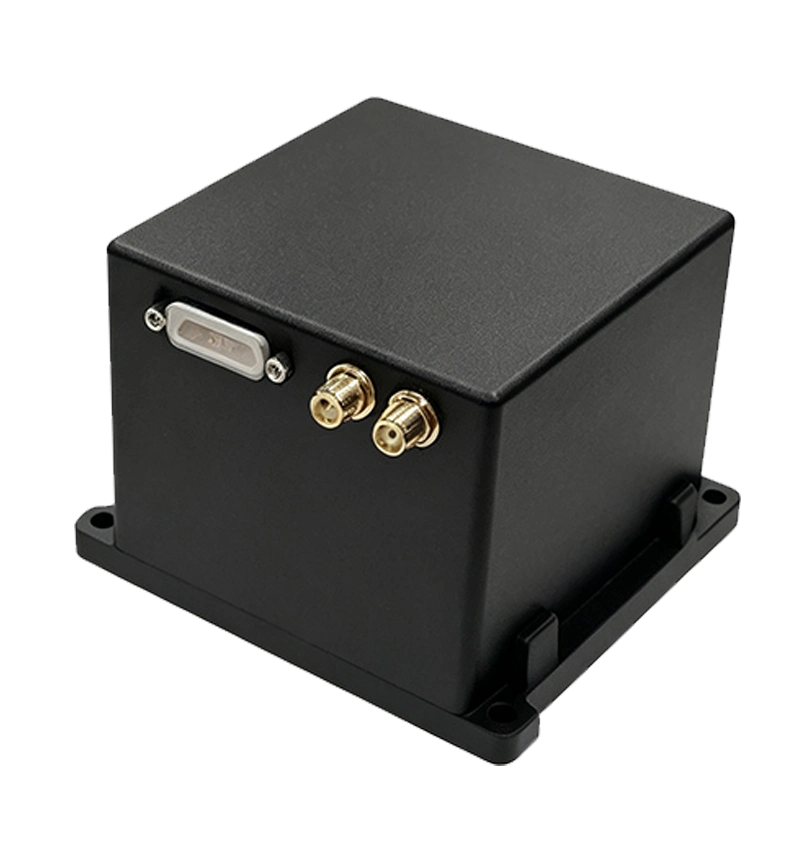
CW-MSS1010 Series
MEMS Integrated Inertial Navigation System
Product Overview
The CW-MSS1010 series integrates high-performance MEMS gyroscopes, MEMS accelerometers and GNSS satellite receiver chips. By sensing the earth's rotation angular rate and acceleration, it performs static self-alignment to obtain the true heading of the carrier. It implements integrated navigation by fusing 3D velocity, position and heading data acquired from the GNSS receiver.
Core Advantages
High-performance, modular and lightweight design. Equipped with abundant interfaces and isolation protection. Supports full-band GNSS signals and RTK differential input, delivering high positioning and orientation accuracy under complex environments. Automatic north-seeking accuracy better than 1°.
Key Features
- High performance, modular structure, low weight
- Rich interfaces with isolation protection design
- Automatic north-seeking accuracy better than 1°
- Supports full-band GNSS, high accuracy in complex environments
- Compatible with RTK differential correction
Main Applications
- Vehicle positioning and attitude measurement
- Mobile mapping and surveying
- Unmanned ground vehicle navigation
- Optoelectronic stabilized platforms
- Dynamic attitude reference systems
Performance Specifications
| Category | Parameter Item | CW-MSS1010 | CW-MSS3010 | CW-MSS5110 | CW-MSA1110 | CW-MSA3110 | CW-MSA5310 |
|---|---|---|---|---|---|---|---|
| Gyroscope | Range (°/s) | ±300 | ±200 | ±400 | ±400 | ±400 | ±500 |
| Full-temperature Bias (°/h, 3σ) | ≤ 0.1 | ≤ 0.3 | ≤ 2 | ≤ 10 | ≤ 80 | ≤ 60 | |
| Bias Stability (°/h, 10s Smooth) | ≤ 0.1 | ≤ 0.1 | ≤ 0.5 | ≤ 1 | ≤ 3 | ≤ 5 | |
| Scale Factor Nonlinearity (ppm) | ≤ 100 | ≤ 100 | ≤ 100 | ≤ 100 | ≤ 100 | ≤ 100 | |
| Accelerometer | Range (g) | ±10 | ±10 | ±30 | ±30 | ±20 | ±40 |
| Full-temperature Bias (mg, 3σ) | ≤ 0.2 | ≤ 0.5 | ≤ 2 | ≤ 2 | ≤ 2 | ≤ 3 | |
| Bias Stability (μg, 10s Smooth) | ≤ 20 | ≤ 20 | ≤ 50 | ≤ 50 | ≤ 50 | ≤ 100 | |
| Scale Factor Nonlinearity (ppm) | ≤ 100 | ≤ 100 | ≤ 100 | ≤ 100 | ≤ 100 | ≤ 100 | |
| Navigation Accuracy | North-seeking Accuracy (°,1σ) | ≤ 0.5 | ≤ 0.5 | ≤ 3 | / | / | / |
| Pure Inertial Accuracy (1σ,60s) | ≤1m/60s | ≤3m/60s | ≤5m/60s | ≤5m/60s | ≤10m/60s | ≤20m/60s | |
| Horizontal Position (m,1σ) | ≤2 (Single) ≤0.02+1ppm (RTK) |
≤2 (Single) ≤0.02+1ppm (RTK) |
≤2 (Single) ≤0.02+1ppm (RTK) |
≤2 (Single) ≤0.02+1ppm (RTK) |
≤2 (Single) ≤0.02+1ppm (RTK) |
≤3 (Single) ≤0.02+1ppm (RTK) |
|
| Vertical Position (m,1σ) | ≤3 (Single) ≤0.03+1ppm (RTK) |
≤3 (Single) ≤0.03+1ppm (RTK) |
≤3 (Single) ≤0.03+1ppm (RTK) |
≤3 (Single) ≤0.03+1ppm (RTK) |
≤3 (Single) ≤0.03+1ppm (RTK) |
≤5 (Single) ≤0.03+1ppm (RTK) |
|
| Horizontal Velocity (m/s,1σ) | ≤0.05 | ≤0.05 | ≤0.05 | ≤0.05 | ≤0.05 | ≤0.1 | |
| Vertical Velocity (m/s,1σ) | ≤0.1 | ≤0.1 | ≤0.1 | ≤0.1 | ≤0.1 | ≤0.15 | |
| Combined Heading (°,1σ) | ≤0.1 (2m baseline dual-antenna) ≤0.15 (Single, dynamic) |
≤0.1 (2m baseline dual-antenna) ≤0.15 (Single, dynamic) |
≤0.1 (2m baseline dual-antenna) ≤0.15 (Single, dynamic) |
≤0.1 (2m baseline dual-antenna) ≤0.2 (Single, dynamic) |
≤0.1 (2m baseline dual-antenna) ≤0.2 (Single, dynamic) |
≤0.15 (2m baseline dual-antenna) ≤0.5 (Single, dynamic) |
|
| Horizontal Attitude (°,1σ) | ≤0.015 (Single, dynamic) ≤0.01 (RTK, dynamic) |
≤0.015 (Single, dynamic) ≤0.01 (RTK, dynamic) |
≤0.015 (Single, dynamic) ≤0.01 (RTK, dynamic) |
≤0.05 (Single, dynamic) ≤0.03 (RTK, dynamic) |
≤0.05 (Single, dynamic) ≤0.03 (RTK, dynamic) |
≤0.05 (Single, dynamic) ≤0.03 (RTK, dynamic) |
|
| Physical Characteristics | Power Supply (V) | 9~36 | 9~36 | 9~36 | 9~36 | 9~36 | 9~36 |
| Steady-state Power (W) | ≤4 | ≤4 | ≤4 | ≤4 | ≤4 | ≤4 | |
| Start-up Time (s) | ≤2 | ≤2 | ≤2 | ≤2 | ≤2 | ≤2 | |
| Update Rate (Hz, max) | 200 | 200 | 200 | 200 | 200 | 200 | |
| Dimension (mm×mm×mm) | 70×66×63 | 70×66×63 | 70×66×63 | 70×66×63 | 70×66×63 | 70×66×63 | |
| Weight (g) | ≤370 | ≤370 | ≤370 | ≤370 | ≤370 | ≤370 | |
| Operating Environment | Operating Temperature (℃) | -45 ~ +80 | -45 ~ +80 | -45 ~ +80 | -45 ~ +80 | -45 ~ +80 | -45 ~ +80 |
| Storage Temperature (℃) | -55 ~ +85 | -55 ~ +85 | -55 ~ +85 | -55 ~ +85 | -55 ~ +85 | -55 ~ +85 | |
| Vibration (g, RMS) | 20~2000, 6.06 | 20~2000, 6.06 | 20~2000, 6.06 | 20~2000, 6.06 | 20~2000, 6.06 | 20~2000, 6.06 | |
| Shock (g) | 500g/1ms | 500g/1ms | 500g/1ms | 500g/1ms | 500g/1ms | 500g/1ms |