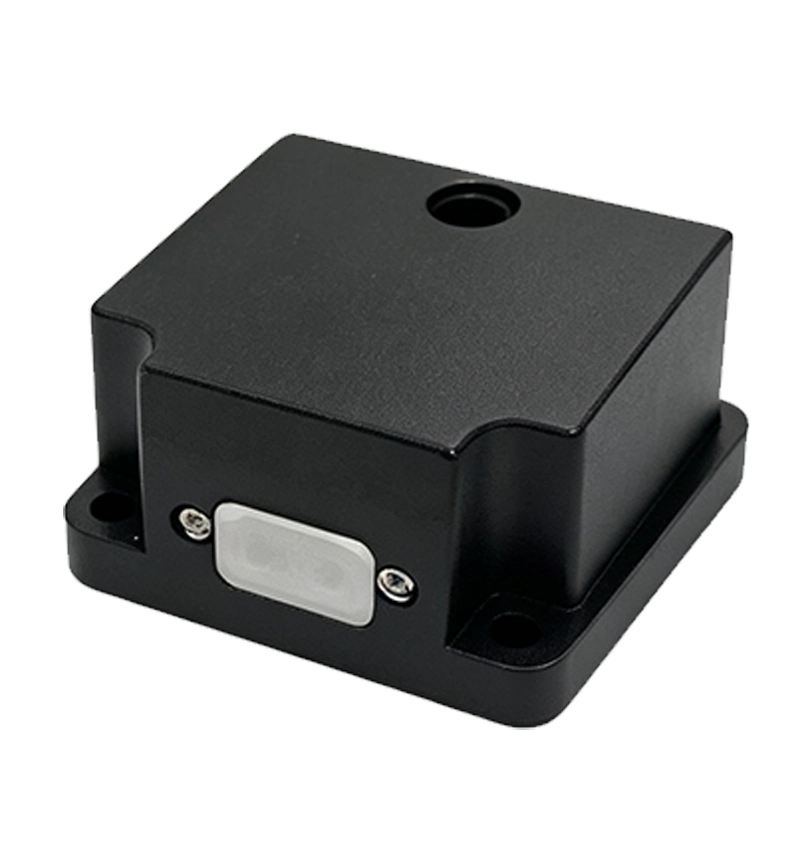
CW-MUA3130
MEMS Inertial Measurement Unit
Product Overview
CW-MUA3130 is a highly reliable and cost-effective six-axis high-precision MEMS inertial sensor. It is widely used in navigation, control and measurement fields represented by inertial navigation and attitude stabilization.
Core Advantages
High performance, small size, light weight and low power consumption; -45℃ ~ +80℃ full-temperature calibration compensation; multi-sensor redundancy and fault-tolerant design; online software upgrade; resistant to harsh mechanical environments; 100% domestic production; high-speed sampling; low cost.
Key Features
- High performance, small size, light weight and low power consumption
- -45℃ ~ +80℃ full-temperature calibration compensation
- Multi-sensor redundancy and fault-tolerant design
- Support software online upgrade
- Resist harsh mechanical environments
- 100% domestic production
- High-speed sampling
- Low cost
Main Applications
- Inertial navigation and attitude stabilization
- UAV flight control & navigation
- Vehicle and marine attitude measurement
- Precision motion measurement
- High dynamic inertial measurement
Performance Specifications
| Category | Parameter Item | CW-MUA3130 |
|---|---|---|
| Gyroscope | Range (°/s) | ±300 |
| Full-temperature Bias (°/h, 3σ) | ≤80 | |
| Bias Stability (°/h, 10s smoothing) | ≤3 | |
| Bias Stability (°/h, allan) | ≤0.5 | |
| Bias Repeatability (°/h) | ≤3 | |
| Angular Random Walk (°/√h) | ≤0.025 | |
| Scale Factor Nonlinearity (ppm) | ≤100 | |
| Cross-coupling (rad) | ≤0.001 | |
| Bandwidth (Hz) | ≥200 | |
| Accelerometer | Range (g) | ±20 |
| Full-temperature Bias (mg, 3σ) | ≤2 | |
| Bias Stability (μg, 10s smoothing) | ≤50 | |
| Bias Stability (μg, allan) | ≤30 | |
| Bias Repeatability (μg) | ≤50 | |
| Velocity Random Walk (m/s/√h) | ≤0.04 | |
| Scale Factor Nonlinearity (ppm, ±1g) | ≤100 | |
| Cross-coupling (rad) | ≤0.001 | |
| Bandwidth (Hz) | ≥200 | |
| Physical Characteristics | Power Supply (V) | 5~12 |
| Steady-state Power (W) | ≤1 | |
| Start-up Time (s) | ≤2 | |
| Update Rate (Hz, max) | 2000 | |
| Dimension (mm×mm×mm) | 44.8×38.6×21.5 | |
| Weight (g) | ≤52 | |
| Operating Environment | Operating Temperature (℃) | -45 ~ +80 |
| Storage Temperature (℃) | -55 ~ +85 | |
| Vibration (g, RMS) | 20~2000Hz, 6.06 | |
| Shock (g) | 1000/1ms |